Open-source robot · Apache-2.0
LeKiwi mobile robot
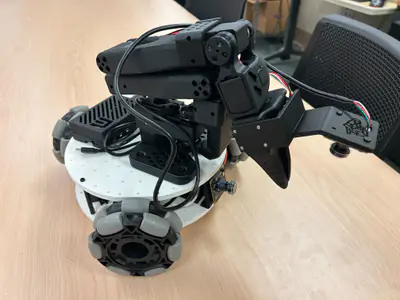
Three-wheel mobile robot with a printable arm. Its project publishes: CAD, print meshes, parts list, and assembly guide; useful modular mounting layout.
Independent open-source projects, not made by or affiliated with Infinomni.
Play it in your browser
Drive the base and pose the arm.
On the real LeKiwi three omni wheels drive it and LeRobot runs it from a laptop, with its cameras. Here a staged carrier moves the base the way its wheels would; the wheels turn to match but do not push it, and there are no cameras and no autonomy.
Opens a simplified model of LeKiwi in the playground, free and with no account (about 0.4 MB).
Free print kit
32 printed pieces for one build, from 34 STL files (the extra files are alternatives and fit gauges). The files are the project’s own, unmodified and at their upstream paths, from SIGRobotics-UIUC/LeKiwi at efa608d7 (SIGRobotics at UIUC) and TheRobotStudio/SO-ARM100 at 7629d2ad (The Robot Studio). The zip adds the licence, a NOTICE crediting the project, a README and SHA-256 sums.
3.3 MB · free, no account.
A few pieces are not in the zip, because they are derived from other people’s models under other terms. Print them from the project:
- 3DPrintMeshes/servo_wheel_hub.stl, 3 pieces. Derived from a VEX VersaHub model, which the project’s licence does not cover.
- 3DPrintMeshes/pi_case_top.stl, 1 piece. Derived from a Micro Center case licensed for non-commercial use only (CC BY-NC).
- 3DPrintMeshes/pi_case_bottom.stl, 1 piece. Derived from a Micro Center case licensed for non-commercial use only (CC BY-NC).
Parts list
This source inventory is frozen. Reviewed purchase links can be updated without changing the parts or quantities recorded here. The list is incomplete and does not verify printed fit, wiring, or physical operation.
5V mobile base and two-arm teleoperation set
| Part | Quantity |
|---|---|
| Mobile Base Structure | |
| 4" Omni wheels | 3 |
| M2 M3 M4 Assorted Screw Set | 1 kit |
| Sensors and Compute | |
| Raspberry Pi 5 (4GB) | 1 |
| USB camera | 2 |
| microSD card | 1 |
| Other | |
| Table Clamp 4pcs | 4 |
| Screwdriver Set | 1 kit |
| USB-C to USB-A Cable 2 pcs | 2 |
| Mobile Base Electronics (5V) | |
| 20000maH 85W Power Bank | 1 |
| STS3215 Servo | 3 |
| USB-C Cable 2pcs (1feet/0.5 m) | 2 |
| USB-C To DC Cable | 1 |
| SO-101 2 Robot Arm Teleoperation Set (5V) | |
| STS3215 Servo | 12 |
| Motor Control Board | 2 |
| Power Supply | 1 |
As the project lists it in BOM.md, captured 2026-10-03. See this list with reviewed buying links.
12V mobile base and two-arm teleoperation set
| Part | Quantity |
|---|---|
| Mobile Base Structure | |
| 4" Omni wheels | 3 |
| M2 M3 M4 Assorted Screw Set | 1 kit |
| Sensors and Compute | |
| Raspberry Pi 5 (4GB) | 1 |
| USB camera | 2 |
| microSD card | 1 |
| Other | |
| Table Clamp 4pcs | 4 |
| Screwdriver Set | 1 kit |
| USB-C to USB-A Cable 2 pcs | 2 |
| Mobile Base Electronics (12V) | |
| 12v 5a Battery | 1 |
| Lever Wire Connector | 1 |
| 12v 5a DC plug connector | 1 |
| 12v to 5v 5a USB-C converter | 1 |
| 12v ST3215 Feetech Servo | 3 |
| SO-101 2 Robot Arm Teleoperation Set (12V) | |
| 12v ST3215 Servo | 12 |
| Motor Control Board | 2 |
| Power Supply | 1 |
As the project lists it in BOM.md, captured 2026-10-03. See this list with reviewed buying links.
Wired mobile base only
| Part | Quantity |
|---|---|
| 4" Omni wheels | 3 |
| M2 M3 M4 Assorted Screw Set | 1 kit |
| USB camera | 2 |
| USB-C to USB-A Cable 2 pcs | 2 |
| USB-C To DC Cable | 1 |
| STS3215 Servo | 3 |
| Motor Control Board | 1 |
| Power Supply | 1 |
| USB Hub | 1 |
| USB-C extension cable | 1 |
As the project lists it in BOM.md, captured 2026-10-03. See this list with reviewed buying links.
Credits and licence
LeKiwi by SIGRobotics at UIUC; its arm parts are the SO-ARM100 by The Robot Studio. Licensed under the Apache License 2.0. The project’s files: SIGRobotics-UIUC/LeKiwi.
The model in the simulator
Converted and simplified by Infinomni from SIGRobotics-UIUC/LeKiwi@efa608d7: its URDF converted to MuJoCo; printable parts decimated; the omni wheels, servos, standoffs, battery, cameras and Raspberry Pi case replaced by plain shapes of the same size; the back drive module moved 20 mm in to match the plate; estimated masses; a staged planar carrier drives the base. Not the original files. Model source · NOTICE.
More open-source robots
- Open Duck Mini v2: Expressive little walking droid.
- SO-101: Six-axis desk robot arm made for teaching robots new skills.
- All of them in Infinomni’s robot list