Open-source robot · Apache-2.0
Open Duck Mini v2
Expressive little walking droid. Its project publishes: printable parts, CAD, parts list, assembly guides, and locomotion code.
Independent open-source projects, not made by or affiliated with Infinomni.
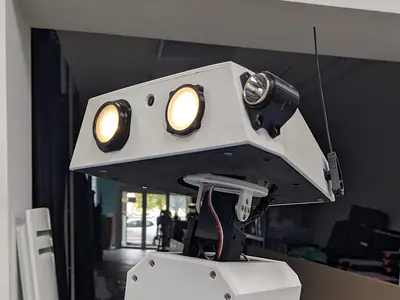
Play it in your browser
Walk, look around, or pose its joints.
The policy was trained for the real duck’s servos; here it drives simulated ones set to the values its project identified, so its gait here is not quite the real duck’s, and it can fall.
Opens a simplified model of the duck, and its own walking policy, in the playground, free and with no account (about 1.4 MB).
Free print kit
51 printed pieces for one build, from 36 STL files (the extra files are alternatives and fit gauges). The files are the project’s own, unmodified and at their upstream paths, from apirrone/Open_Duck_Mini at b23317a4 (Antoine Pirrone and the Open Duck Mini contributors). The zip adds the licence, a NOTICE crediting the project, a README and SHA-256 sums.
Download open-duck-mini-v2-print-kit.zip
2.7 MB · free, no account.
Parts list
This source inventory is frozen. Reviewed purchase links can be updated without changing the parts or quantities recorded here. The list is incomplete and does not verify printed fit, wiring, or physical operation.
Main robot; expression add-ons excluded
| Part | Quantity |
|---|---|
| 18650 cell | 2 |
| 18650 cell holder | 1 |
| 2S BMS | 1 |
| 5V regulator | 1 |
| Small power switch | 1 |
| usb-c charger | 1 |
| 2.1mm barrel jack | 2 |
| XT15? XT30 ? | 1 |
| IMU (BNO055) | 1 |
| Raspberry pi zero 2w | 1 |
| SD card | 1 |
| Servo control board | 1 |
| Feetech 7.4v STS 3215 | 14 |
| Feet contact switches (SS-10) | 4 |
| 9g servos | 2 |
| 3D printing M3 inserts | 1 |
| Standard PLA | 1 |
| TPU | 1 |
| Cable sheath | 1 |
| 15cm micro usb to usb-c cable | 1 |
| 50cm micro usb to usb c cable | 1 |
| Bearing | 3 |
As the project lists it in its parts spreadsheet, captured 2026-10-03. See this list with reviewed buying links.
Credits and licence
Open Duck Mini by Antoine Pirrone and the Open Duck Mini contributors. Licensed under the Apache License 2.0. The project’s files: apirrone/Open_Duck_Mini.
The model in the simulator
Simplified by Infinomni from apirrone/Open_Duck_Mini@b23317a4: printable parts decimated; servos, boards, battery and other bought parts, and the antenna rods, replaced by plain shapes of the same size; the free joint its file leaves commented out restored; the servo values its file keeps commented out used; stood in the bent-knee pose its policy runner starts from; its walking policy converted from ONNX to plain float32, unchanged in value. Not the original files. Model source · NOTICE.
More open-source robots
- LeKiwi: Three-wheel mobile robot with a printable arm.
- SO-101: Six-axis desk robot arm made for teaching robots new skills.
- All of them in Infinomni’s robot list